Result assessor view · example
What the assessor gets
This is an excerpt from the evidence package of the L2 demo. It is based on the same graph as the Analyze demo, but presented as a sealed, checkable record rather than an interactive explorer.
868ac61b…Claim → evidence → status
Five rows from the package: two are proven, three are not. The SG-3 row shows the same gap as Path B in the Analyze demo.
| Claim | Evidence | Status | Note |
|---|---|---|---|
| SG-1 Lane keeping | Test run · Trace | proven | Link and timing are traceable. |
| SG-3 Steering torque | Test run (green) | not load-bearing | The safety goal was tightened to 150 ms, but the test still checks 200 ms. |
| SG-4 Distance | SYS requirement | open | The software link is missing and the decomposition is incomplete. |
| SG-5 Actuator | Review | open | Timing evidence is absent. |
| TSR-003 Torque limit | Test run · Trace | proven | The evidence chain along the torque path is closed. |
One gap in detail
Here you see the same gap twice: as an image from the explorer and as a row in the report.
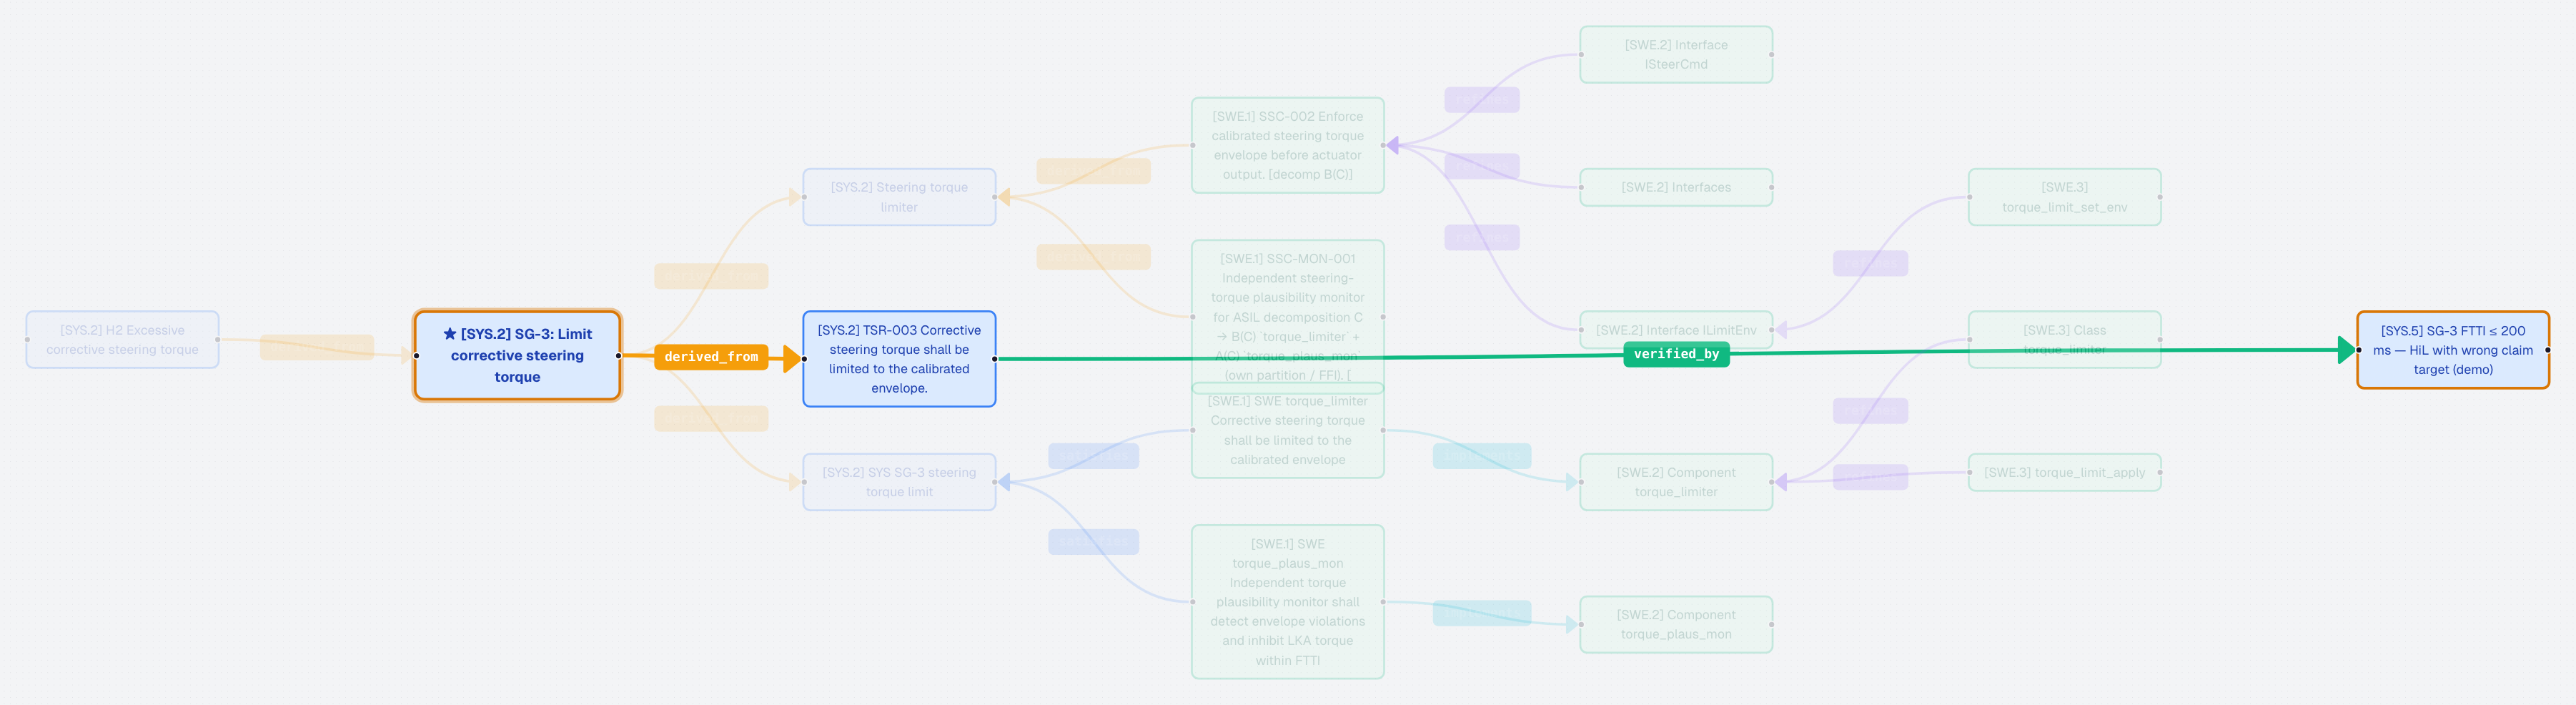
The test is green and does not prove the safety goal
The safety goal was tightened from 200 ms to a maximum of 150 ms, but the test was not updated. It still passes, but it does not support the current requirement. The package therefore lists this row as “not load-bearing”, not “passed”.
This package is sealed. Any change to the input data produces a different hash and thus becomes visible.
Demo state October 2026 · not a certificate, not a release · Hash 868ac61b…
Next
Your project
In the Reality Check we clarify together whether viprove fits your project.
Request a Reality Check →Full example package
The full evidence package of this demo is in preparation. We are happy to send it to you as soon as it is available.
Request the example package →Second instance: robotics
The same pattern with a different norm reference: performance levels instead of ASIL.
To the robotics demo →