B1 · Proof · Robot cell Sensor simulated
The safety zone is not a drawing.
It is a calculation.
ISO 13855:2024 derives the minimum distance from response time, approach speed and sensor geometry. The cell demonstrates it on video — every millimeter cites its standard.
Prove the safety zone — without sampling.
Safety-zone evidence today is manual work: dimensions from drawings, spot checks at the cell, a report written afterwards. Meanwhile the trend moves toward fenceless, collaborative cells: without a guard fence, sensing and SSM carry the safety function alone — and every change to the cell needs the evidence again.
Measure the scene, calculate S_min per ISO 13855:2024, run the SIL test in the twin — the protocol writes itself while the run is in progress.
The arm stops before the zone. Protocol #0117 is sealed, every millimetre carries a standard reference.
Reproducible instead of sampled: same setup, same result — and traceable down to the standards chain in any audit. Collaborative cells per ISO/TS 15066: SSM is one of the four collaboration methods — here calculated per ISO 13855:2024 and proven in the SIL test.
The protocol writes itself during the SIL test.
No report written afterwards. While the test runner executes the script, the protocol writes itself — every step timestamped, every value checked against the standard: scan, geometry, S_min, sensor verification, sealing. Time-synchronized with the recording, restarted on every loop.
▸ d = 520 mm → zone holds · ESPE type 3 · IEC 61496-3-3
520 millimeters — computed, not guessed.
Move the controls: every value flows from a clause of ISO 13855:2024 — K and T for approach and response, DDS for reach, Z for measurement uncertainty. The cell's values are one preset among many.
Where the numbers come from.
No value stands alone: the graph shows which standard feeds which parameter into 13855 — and what changed with the 2010 → 2024 edition. Traversing a node is tracing the calculation back through the standards chain.
What changed — and what didn't.
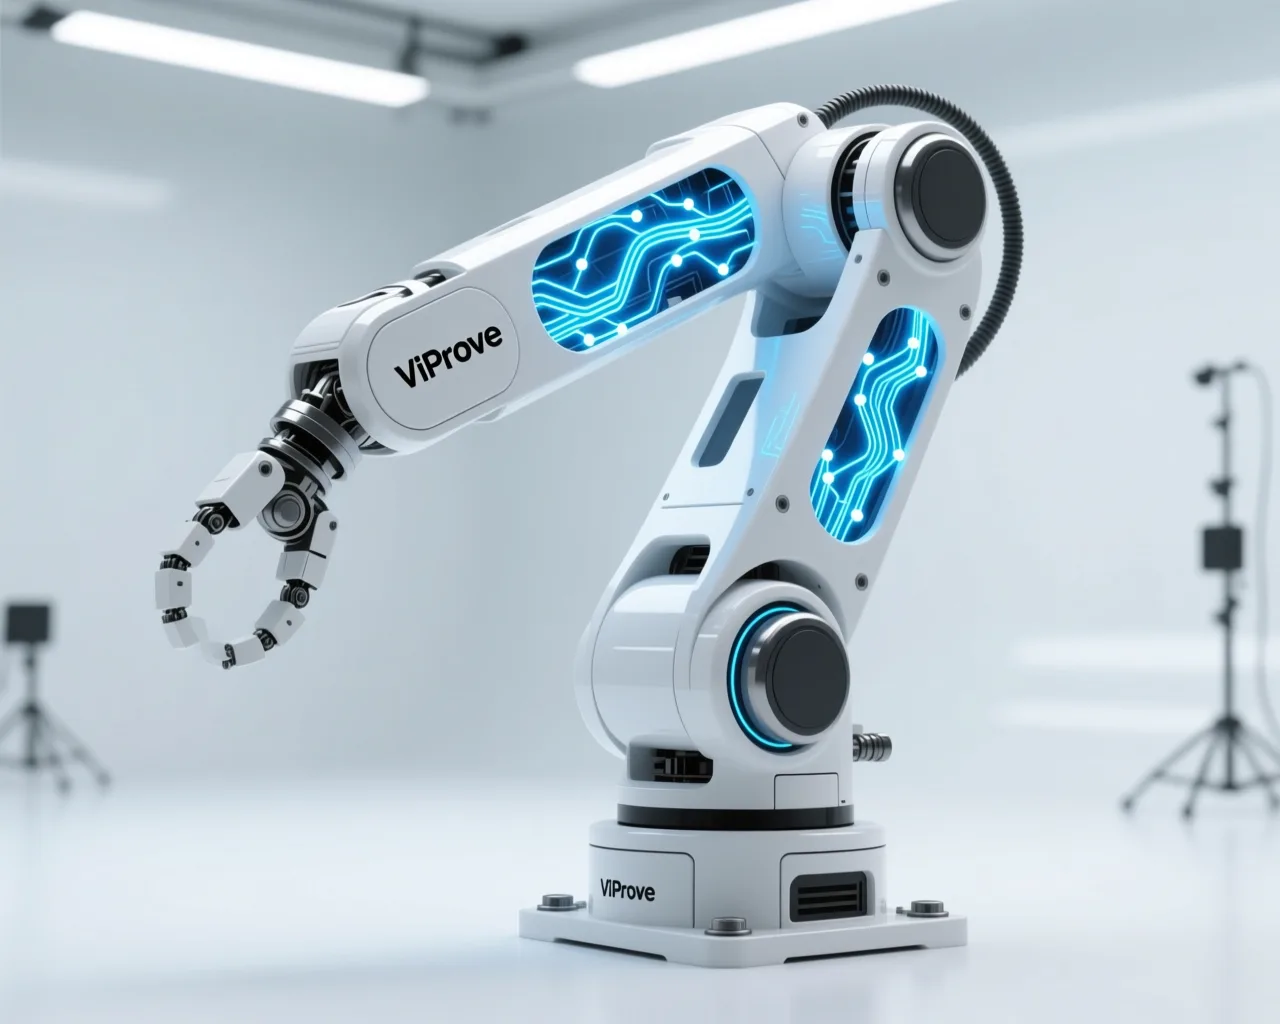
The same cell — with the arm in motion.
The video shows the SIL test with the arm at rest. The SIL simulation moves the arm: safety zones, stopping behaviour, SSM verification — as a digital twin in your browser.
Open the SIL simulation →On record, not just claimed.
The zone is not only measured on video — it is tested and sealed. The demo and the full test report are public.
Every measurement becomes a node.
Reads
3D-ToF point cloud · distances to the zone boundary · from recording (sensor sim)
Transforms
Zone node + S_min edge · S=(K×T)+DDS+Z as an executable rule (ViFACTS!)
Writes back
Sealed protocol #0117 · measurement bar · verdict: SIL run approved
Honest status.
What runs, what is simulated, what is still unproven — as of 2026-07-30.